AgiBot D1 Edu
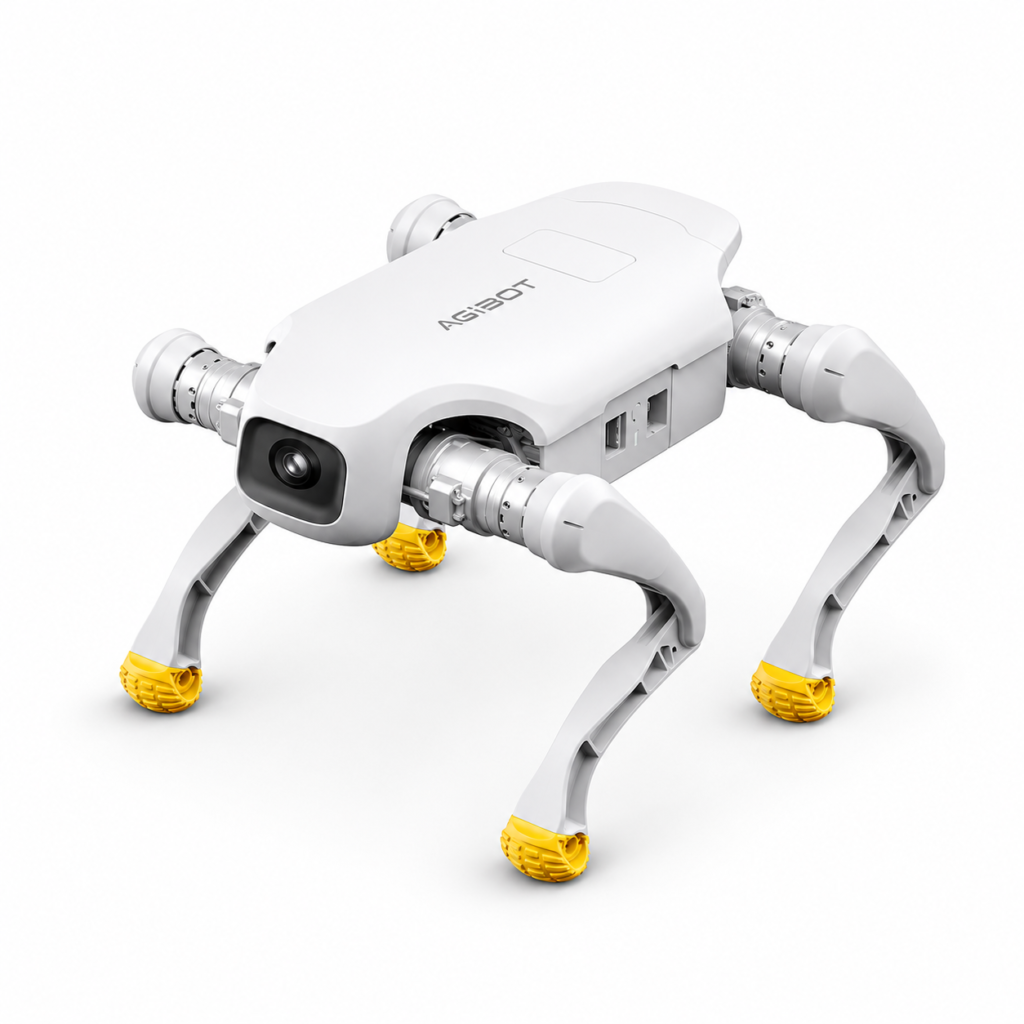
Flexible development on a robust quadruped platform
The D1 platform with secondary development enabled. It adds an SDK, simulation models and expansion interfaces for labs and teaching.
- 15.5 kg
- Weight
- 3.5 m/s
- Max speed
- 1 to 2 h
- Endurance
- 6 km ± 1 km
- Range
- Brand
- AgiBot
- Type
- Quadruped robots
- Industries
- Education
Overview
A 15.5 kg robot dog that walks on varied terrain with reinforcement-learning gait control, with self-balancing, anti-fall and anti-interference behavior. Its motors reach 48 N·m peak torque. It climbs 16 cm stairs, slopes up to 40° and jumps 35 cm. The D1 Edu adds secondary development: an SDK for payload integration, URDF models for simulation in Isaac Sim and MuJoCo, and standard interfaces for modules such as positioning, LiDAR, depth cameras, RTK, 4G/5G and image transmission. Specifications come from manufacturer laboratory tests and real performance varies with environment and use.
Good for: Robotics labs, university teaching, research and payload integration
Specifications
| Weight | 15.5 kg |
|---|---|
| Dimensions | 635 x 360 x 420 mm (standing) mm |
Manufacturer specifications
| Standing size | About 635 x 360 x 420 mm (L x W x H) |
|---|---|
| Lying size | About 675 x 435 x 145 mm (L x W x H) |
| Weight | 15.5 kg, including battery |
| Material | Aluminum alloy and high-strength engineering plastic |
| Max speed | 3.5 m/s |
| Effective payload | 5 kg |
| Continuous stair climb | 16 cm |
| Max climbing slope | 40° |
| Jump height | 35 cm off the ground |
| Joint motors | 12 precision motors, aluminum alloy; dual encoders, no zero calibration needed |
| Max joint torque | 48 N·m |
| Max power output | 3500 W |
| Joint range, body | -28° to 28° |
| Joint range, thigh | -170° to 66° |
| Joint range, lower leg | 35° to 156° |
| Camera field of view | DFOV 122°, HFOV 111°, VFOV 70° |
| IMU | Standard |
| Computing | 8-core high-performance CPU |
| Battery | Nominal 4.6 Ah, 43.2 V |
| Endurance | 1 to 2 h |
| Range | 6 km ± 1 km |
| Charging time | About 1 h (10% to 90%) |
| Operating temperature | 0 °C to 40 °C |
| Standard actions | Standing, lying, damping mode, pitch adjustment, height adjustment, horizontal turning |
| Special actions | Forward jump, upward jump, biped standing, backflip, waving |
| Live video | Real-time image transmission supported |
| In the box | Robot dog platform, charger, handheld remote |
| Warranty | 1 year (manufacturer's terms) |
| Note | Specifications come from manufacturer laboratory tests; real performance varies with environment and use |
| Secondary development | Supported, with an SDK development kit |
| Expansion interfaces | Ethernet, USB, power port, SBUS port, UART port |
| Simulation | URDF models for Isaac Sim and MuJoCo |
| Compatible modules | Positioning, LiDAR, depth cameras, RTK, 4G/5G, image transmission |
Applications
Demonstrations and events|Education and training|Research and development|Terrain locomotion tests