AgiBot D1 Max
A productivity platform built for industry
A 41 kg wheel-legged quadruped with IP67 protection, a 25 kg rated payload and up to 5 hours of endurance. Built for outdoor and industrial work.
- 12+4
- Degrees of freedom
- IP67
- Protection
- 25 kg
- Rated payload
- 6 m/s
- Max speed
- Brand
- AgiBot
- Type
- Quadruped robots
- Industries
- Industrial · Logistics
Overview
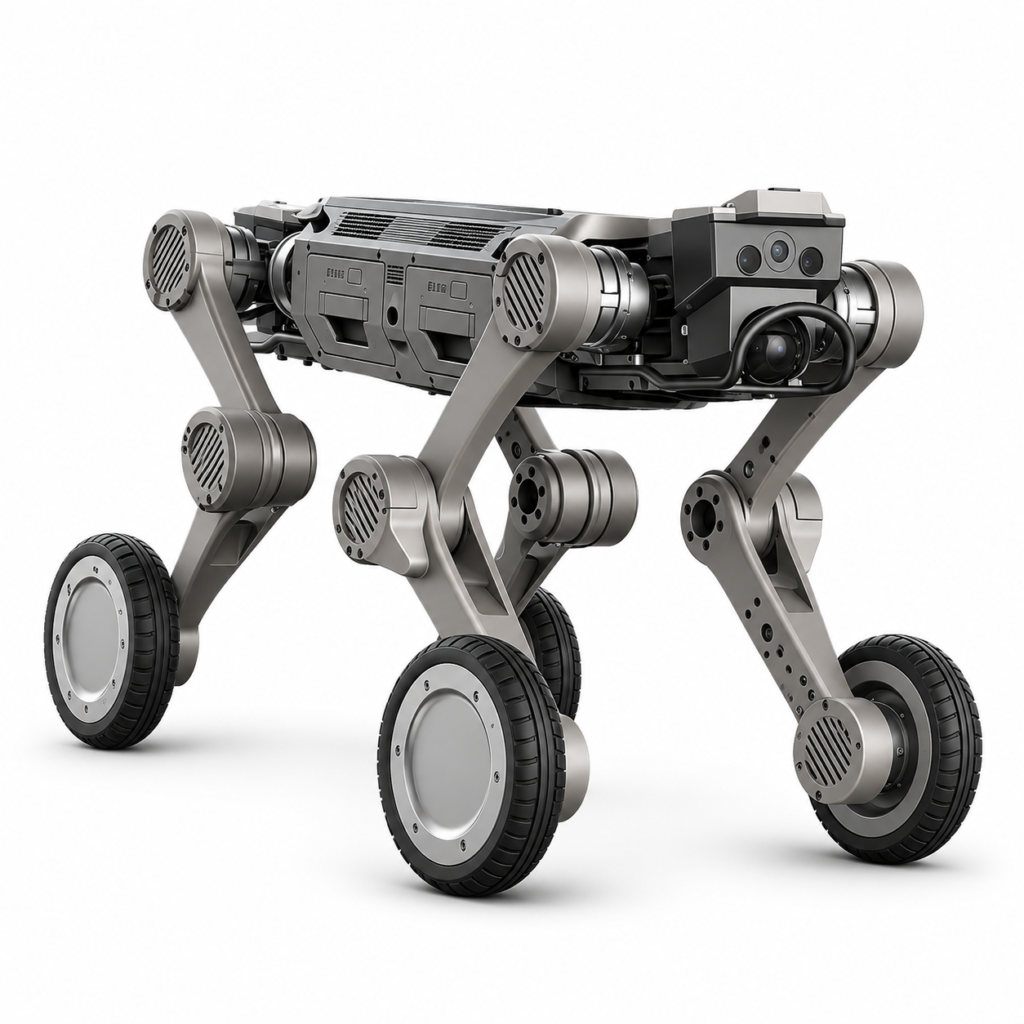
The D1 Max is a wheel-legged quadruped robot built for industry. It is rated IP67 for rain, dust and humidity and is designed for long outdoor and industrial use. It carries a 25 kg rated payload, climbs 45° slopes and crosses obstacles up to 80 cm. Wheel mode gives stable, efficient movement with longer runtime, and leg mode gives better terrain adaptability. Two hot-swappable batteries reduce downtime. It has front and rear LiDAR and cameras, RTK, a 157 TOPS compute module and a set of power and communication interfaces for secondary development and industrial integration. Specifications come from manufacturer laboratory tests and real performance varies with environment and use.
Good for: Logistics and transport, search and rescue, and task execution in outdoor and industrial sites
Specifications
| Weight | 41 kg |
|---|---|
| Dimensions | 930 x 480 x 585 mm (standing) mm |
Manufacturer specifications
| Standing size | 930 x 480 x 585 mm (L x W x H) |
|---|---|
| Lying size | 930 x 630 x 200 mm (L x W x H) |
| Weight | 41 kg, including battery |
| Frame material | Aluminum alloy with high-strength engineering plastic |
| Structure | Wheel-legged, with wheel mode and leg mode |
| Degrees of freedom | 12+4 |
| Protection | IP67 |
| Operating temperature | -20 °C to 55 °C |
| Rated payload | 25 kg |
| Max speed | 6 m/s |
| Continuous stair climb | 25 cm |
| Max climbing angle | 45° |
| Max obstacle crossing | 80 cm (50 cm with load) |
| Crawling height | 34 ± 0.5 cm |
| Turning | On-the-spot rotation, forward/backward switching |
| Max joint torque | 150 N·m |
| Joint range, body | -30° to 40° |
| Joint range, thigh | -160° to 160° |
| Joint range, calf | -160° to 160° |
| Battery | 2 x 504.9 Wh, quick-swap and hot-swappable |
| Endurance | 5 ± 0.5 h unloaded; 3.5 ± 0.5 h fully loaded |
| Range | 29 ± 1 km unloaded; 18 ± 1 km fully loaded |
| Charging time | Under 1.5 h |
| Compute | 157 TOPS, NVIDIA Orin NX 16GB |
| LiDAR | Two 96-line units (front and rear); 360° x 90° coverage; 120 m detection diameter |
| Cameras | Two 8 MP industrial FPV cameras (front and rear); DFOV 122°, HFOV 111°, VFOV 70° |
| Fill lights | 4 lights; illumination range at least 3 m |
| Other sensors | Automotive-grade IMU, GNSS RTK, ultrasonic sensor on each side (up to 5 m) |
| Wireless | Wi-Fi 5.0 (2.4 GHz), Bluetooth 5.0 |
| Power outputs | 5 V, 12 V, 24 V, 48 V; 480 W maximum in total |
| Expansion ports | 2 x Gigabit Ethernet, 2 x USB 3.0, 1 x RS-232, 1 x RS-485, 2 x SBUS, 1 x PPS |
| Remote control | Screen remote, 700 to 1000 m range |
| Charging dock | Dual battery charging dock standard; autonomous charging dock optional |
| In the box | Robot, G20 remote control, 2 batteries, aviation-grade carrying case, dual battery charging dock, power cords, maintenance tool kit, aviation connector cable set, user manual, certificate of conformity, packing list |
| Note | Specifications come from manufacturer laboratory tests; real performance varies with environment and use |
Applications
Logistics and transport|Personnel search and rescue|Task execution