AgiBot D1 Ultra
Industrial-grade compact quadruped robot
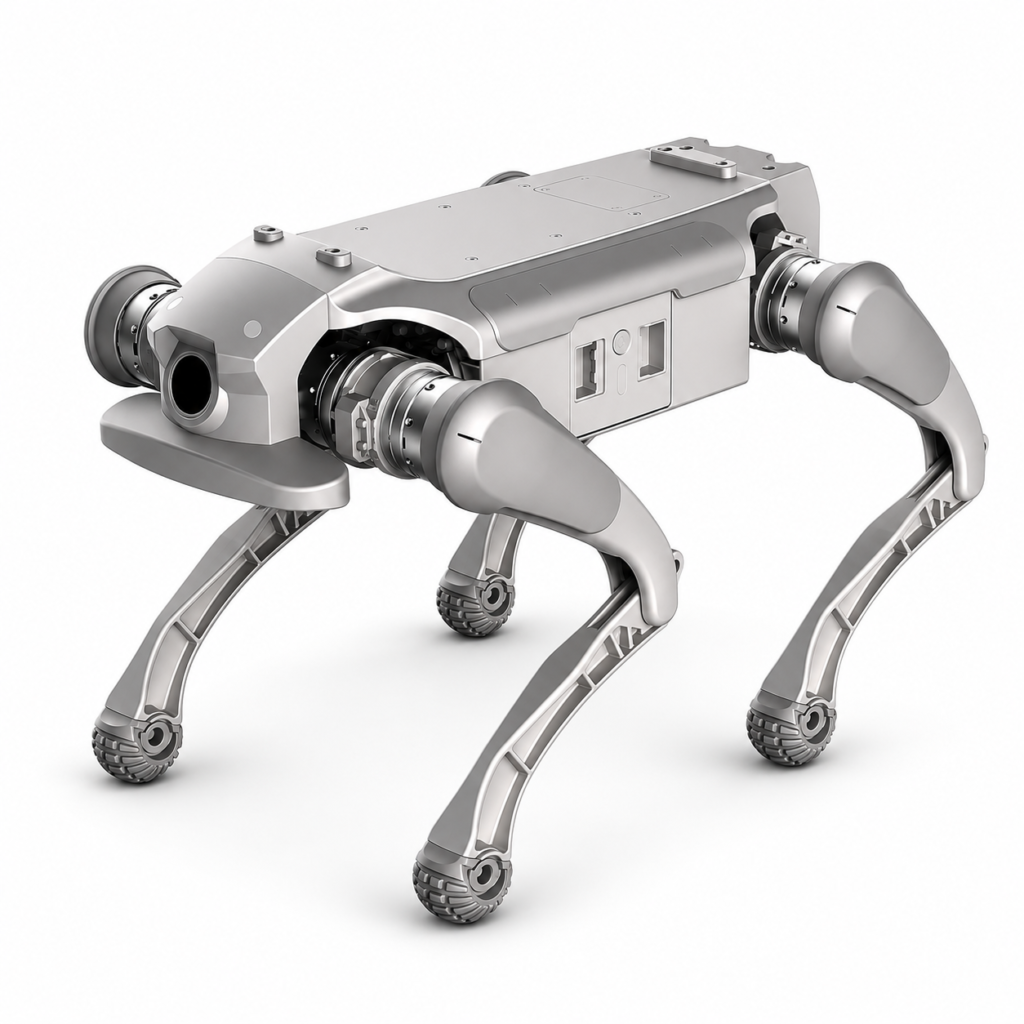
A compact 16 kg quadruped with IP54 protection, 3.7 m/s top speed and a 5 kg payload. It has an open SDK and expansion interfaces for sensors and modules.
- 16 kg
- Weight
- IP54
- Protection
- 3.7 m/s
- Max speed
- 6 ± 1 km
- Range
- Brand
- AgiBot
- Type
- Quadruped robots
- Industries
- EducationIndustrial
Overview
The D1 Ultra is a compact quadruped robot built for multi-scenario industry use. Its structure is dustproof and waterproof (IP54) and meant for splashing, damp, muddy and sandy conditions. Reinforcement-learning gait control keeps it balanced and lets it recover from pushes. It jumps up to 35 cm, climbs 16 cm stairs and handles slopes up to 40°. High-torque motors reach about 48 N·m peak. An open SDK and standard interfaces let you add modules such as LiDAR, depth cameras, RTK, 4G/5G and image transmission, and URDF models support simulation in Isaac Sim and MuJoCo. The intelligent follow function requires your own secondary development. Specifications come from manufacturer laboratory tests and real performance varies with environment and use.
Good for: Security patrol, inspection, research and education
Specifications
| Weight | 16 kg |
|---|---|
| Dimensions | 630 x 360 x 420 mm (standing) mm |
Manufacturer specifications
| Standing size | 630 x 360 x 420 mm (L x W x H) |
|---|---|
| Lying size | 670 x 435 x 145 mm (L x W x H) |
| Weight | 16 kg, including battery |
| Protection | IP54 |
| Stable operating time in extreme environments | 200 h |
| Max speed | 3.7 m/s |
| Effective payload | 5 kg |
| Range | 6 ± 1 km |
| Continuous stair climb | 16 cm |
| Jump height | Up to 35 cm (forward and upward) |
| Max slope | 40° |
| Joint motors | Dual encoders, no zero calibration needed; peak torque about 48 N·m |
| Control | Standard reinforcement-learning gait control with self-balancing, anti-tipping and disturbance rejection |
| Battery | Rated 4.6 Ah, 43.2 V |
| Expansion interfaces | Ethernet, USB, power, SBUS, UART |
| Supported expansion | 3D radar, depth camera, RTK, 4G module, image transmission module, follow-up module, application-layer loading |
| Secondary development | Open SDK; URDF models for Isaac Sim and MuJoCo |
| Intelligent follow | Requires secondary development by the user |
| Build | Dustproof and waterproof structure; vacuum press-formed aluminum alloy shafts; sealed and anti-corrosion core components |
| Note | Specifications come from manufacturer laboratory tests; real performance varies with environment and use |
Applications
Security patrol|Scientific research and education|Emergency rescue|Inspection|Entertainment