Allegro Hand V4
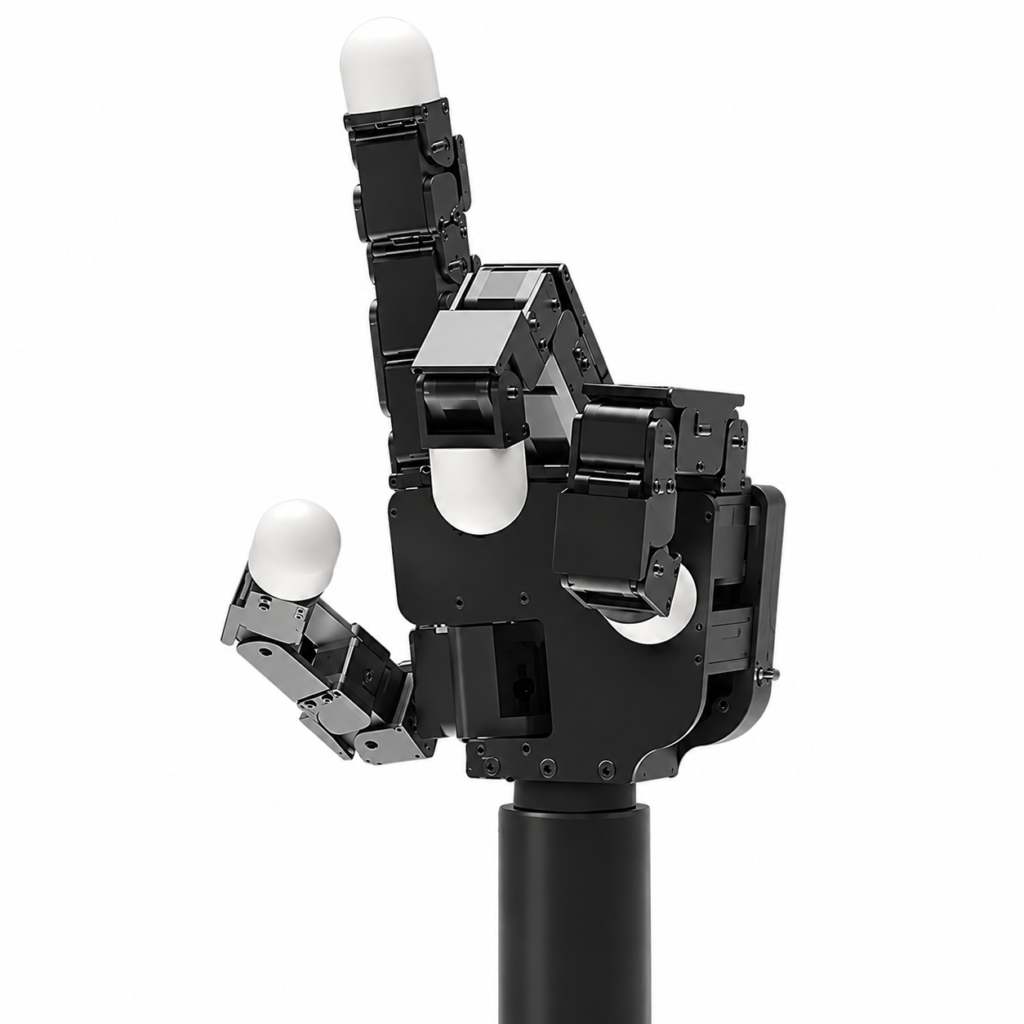
Cost-effective, adaptive four-finger robotic hand
A four-finger robotic hand with sixteen independent torque-controlled joints, for grasping and manipulation research.
- Four
- Fingers
- 16 independent, torque-controlled
- Joints
- DC Motor
- Type
- 5 kg
- Payload
- Brand
- Wonik Robotics
- Type
- Robotic hands
- Industries
- Education
Overview
The Allegro Hand V4 is a cost-effective and highly adaptive robotic hand. It has four fingers and sixteen independent torque-controlled joints, making it a platform for grasping and manipulation research and education.
Good for: Research labs, manipulation and grasping research, universities
Specifications
Manufacturer specifications
| Fingers | Four |
|---|---|
| Joints | 16 independent, torque-controlled |
| Type | DC Motor |
| Gear Ratio | 1:369 |
| Max. Torque | 0.70 (Nm) |
| Max. Joint Speed | 0.11 (sec/60°) |
| Measurement | Potentiometer |
| Resolution (nominal) | 0.002 deg |
| Frequency | 333 Hz |
| Payload | 5 kg |
| Power Requirement | 24V / 100W |
Applications
Grasping and manipulation research|Robot arm integration|Education and research