Allegro Hand V5 3F
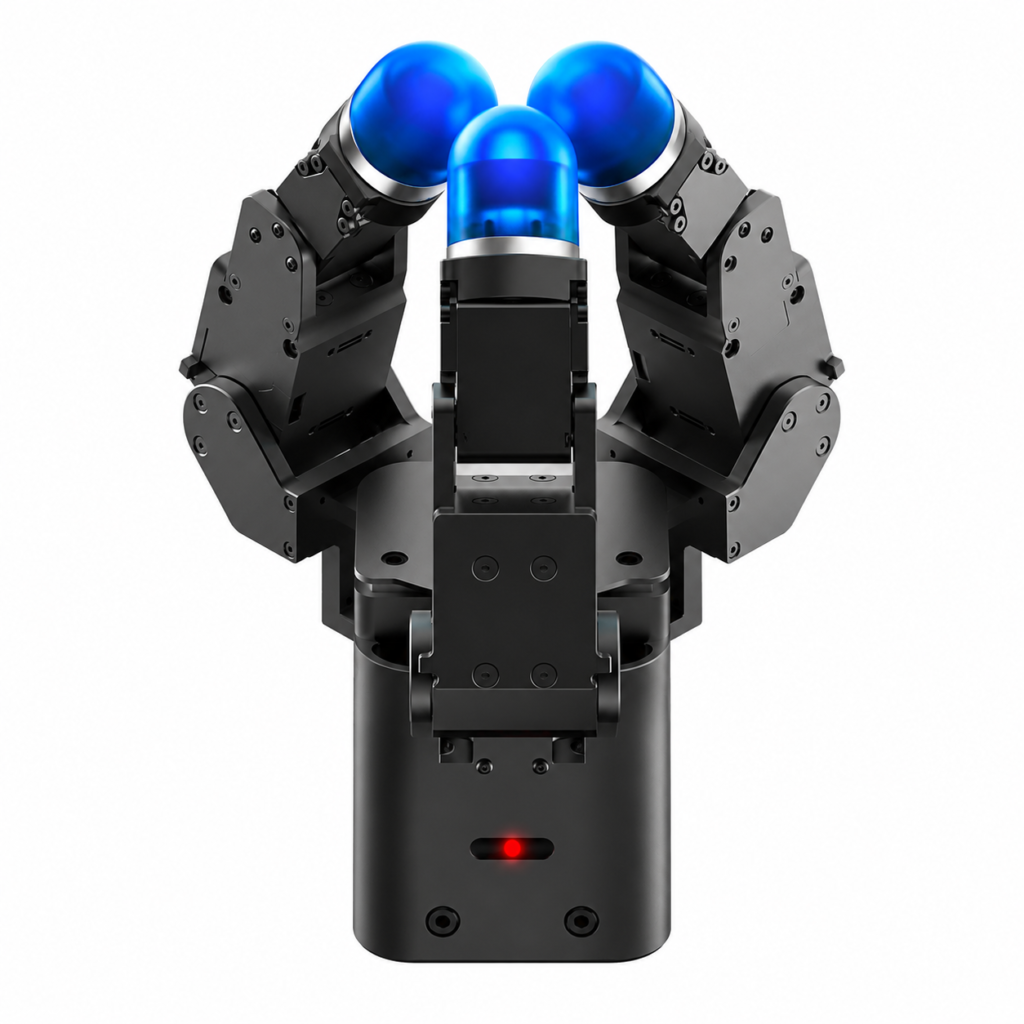
Compact three-finger robotic hand with tactile sensing
A compact three-finger robotic hand with a simple, robust 9-DOF structure and omnidirectional tactile sensors.
- Three
- Fingers
- 9
- Degrees of freedom
- 1,050 g
- Weight
- 0.088 deg
- Joint Resolution
- Brand
- Wonik Robotics
- Type
- Robotic hands
- Industries
- Education
Overview
The Allegro Hand V5 is a smaller configuration of the V5 line. It has a simple and robust design based on a 9-DOF structure, with 360° omnidirectional pneumatic tactile sensors that detect pressure. It can be integrated with robot arms for manipulation research.
Good for: Research labs, manipulation and grasping research, universities
Specifications
Manufacturer specifications
| Fingers | Three |
|---|---|
| Degrees of freedom | 9 |
| Tactile sensing | 360° omnidirectional pneumatic tactile sensors (pressure) |
| Degrees of Freedom | 3 Fingers × 3 = 9 (Active) |
| Type | DC Motor |
| Gear Ratio | 288.35:1 / 159.59:1 (2nd joint of a finger) |
| Stall Torque | 0.92 Nm / 1.6 Nm (2nd joint of a finger) |
| Nominal Torque | 0.23 Nm / 0.48 Nm (2nd joint of a finger) |
| Payload | 12 kg (depending on the measurement method) |
| Weight | 1,050 g |
| Joint Resolution | 0.088 deg |
| Power Requirement | 24.0 V / 5.0 A / 120 W |
Applications
Grasping and manipulation research|Robot arm integration|Education and research